What Is the Parallel Axis Theorem?
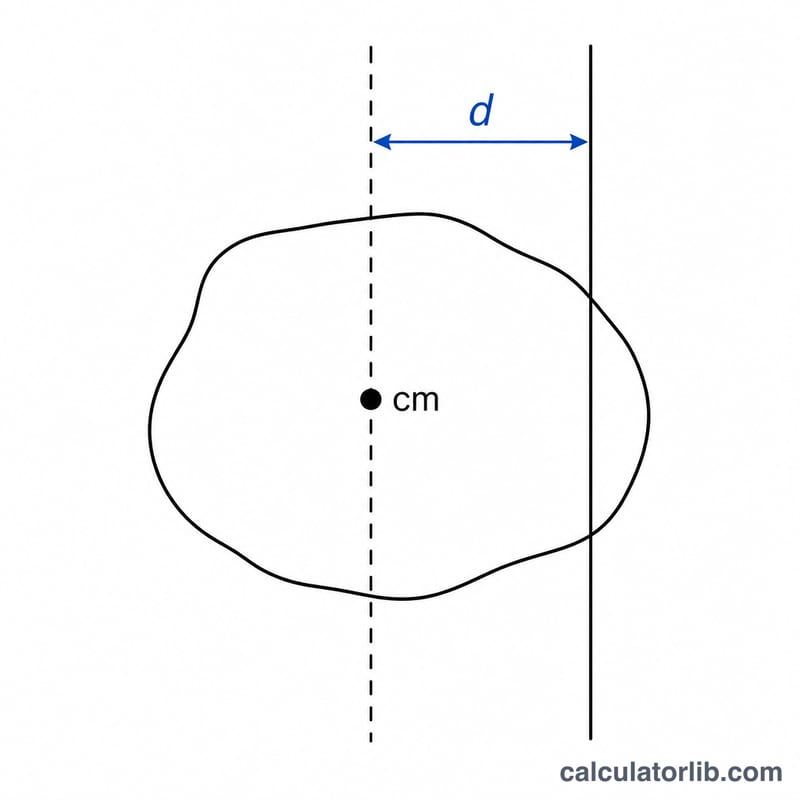
The parallel axis theorem (also called the Huygens–Steiner theorem) lets you find the moment of inertia of a rigid body about any axis, as long as you know the moment of inertia about a parallel axis passing through the body's center of mass. It states that $$I = I_{cm} + m \cdot d^{2}$$ where \(I_{cm}\) is the inertia about the center-of-mass axis, \(m\) is the total mass, and \(d\) is the perpendicular distance between the two parallel axes.
How to Use This Calculator
Enter three values: the moment of inertia about the center of mass (\(I_{cm}\)) in kg\(\cdot\)m², the object's mass (\(m\)) in kilograms, and the distance (\(d\)) in meters between the center-of-mass axis and your new axis of rotation. The calculator multiplies \(m\) by \(d^{2}\) to get the shift term, then adds \(I_{cm}\) to give the total moment of inertia about the new axis.
The Formula Explained
Because moving the rotation axis away from the center of mass always increases the moment of inertia, the \(m \cdot d^{2}\) term is always positive (or zero when the axes coincide). The center of mass is the unique axis location that minimizes the moment of inertia, which is why \(I_{cm}\) is the baseline. The theorem works for any rigid body and any pair of parallel axes.
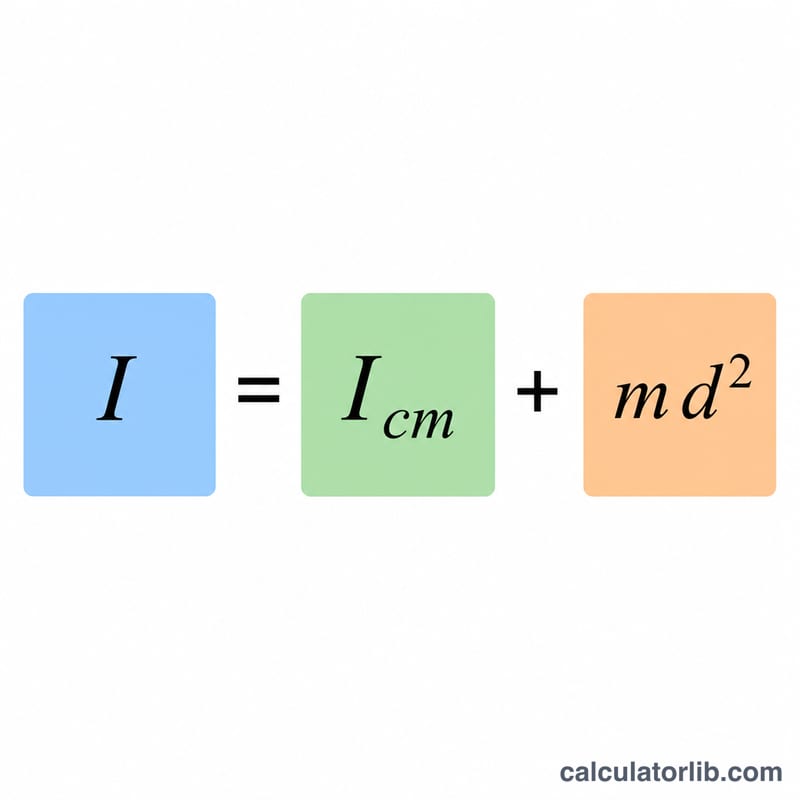
Worked Example
A uniform rod of mass 10 kg has a moment of inertia of 0.5 kg\(\cdot\)m² about its center of mass. To find its inertia about an axis 2 m away: $$\text{shift} = m \cdot d^{2} = 10 \times 2^{2} = 40 \text{ kg}\cdot\text{m}^{2}$$ $$\text{Total } I = 0.5 + 40 = 40.5 \text{ kg}\cdot\text{m}^{2}$$
Standard Moments of Inertia About the Center of Mass
These are the values of \(I_{cm}\) for uniform (constant-density) rigid bodies about an axis through the center of mass. Use them as the \(I_{cm}\) input of the parallel axis theorem \(I = I_{cm} + m d^2\). Here \(m\) is mass, \(L\) is length, \(R\) is radius, and \(a\), \(b\) are the plate side lengths.
| Body | Axis through center of mass | \(I_{cm}\) |
|---|---|---|
| Thin rod, length \(L\) | Perpendicular to the rod, through its center | \(\frac{1}{12} m L^2\) |
| Solid cylinder or disk, radius \(R\) | Its symmetry axis | \(\frac{1}{2} m R^2\) |
| Solid sphere, radius \(R\) | Any axis through the center | \(\frac{2}{5} m R^2\) |
| Hollow thin spherical shell, radius \(R\) | Any axis through the center | \(\frac{2}{3} m R^2\) |
| Thin hoop (ring), radius \(R\) | Symmetry axis, perpendicular to the plane of the hoop | \(m R^2\) |
| Rectangular plate, sides \(a\) and \(b\) | Perpendicular to the plate, through its center | \(\frac{1}{12} m (a^2 + b^2)\) |
Parallel-axis example: rod about its end. The end of the rod is \(d = L/2\) from the center, so
$$I_{end} = \frac{1}{12} m L^2 + m\left(\frac{L}{2}\right)^2 = \frac{1}{12} m L^2 + \frac{3}{12} m L^2 = \frac{1}{3} m L^2$$
The end-axis value is four times the center-axis value.
Comparing Different Axis Distances
Take a body with fixed mass \(m = 10\) kg and \(I_{cm} = 0.5\) kg·m². Moving the axis farther from the center of mass adds \(m d^2\), which grows with the square of the distance.
| d (m) | m·d² (kg·m²) | Total I (kg·m²) | Ratio I / I_cm |
|---|---|---|---|
| 0 | 0 | 0.5 | 1 |
| 0.1 | 10 × 0.1² = 0.1 | 0.6 | 1.2 |
| 0.5 | 10 × 0.5² = 2.5 | 3 | 6 |
| 1 | 10 × 1² = 10 | 10.5 | 21 |
| 2 | 10 × 2² = 40 | 40.5 | 81 |
Doubling the distance from 1 m to 2 m multiplies the \(m d^2\) term by 4. At large \(d\) the total is dominated by \(m d^2\), and \(I_{cm}\) becomes a small correction. The minimum moment of inertia over all parallel axes is always the one through the center of mass (\(d = 0\)).
Definitions & Glossary
- Moment of inertia (I)
- A measure of a body's resistance to changes in its rotation about a given axis. For point masses, \(I = \sum m_i r_i^2\). The SI unit is kg·m².
- Center of mass
- The mass-weighted average position of a body. For a uniform body in a uniform gravitational field it coincides with the center of gravity. Its SI unit of position is the metre (m).
- Rigid body
- An idealized body whose points keep fixed distances from one another, so it does not deform while it rotates or translates.
- Axis of rotation
- The line about which the body rotates, or about which the moment of inertia is evaluated. The value of \(I\) depends on which axis is chosen.
- Perpendicular distance (d)
- The shortest distance between the axis through the center of mass and the parallel axis of interest, in metres (m). It enters the theorem squared.
- Huygens–Steiner theorem (parallel axis theorem)
- The moment of inertia about any axis parallel to one through the center of mass is \(I = I_{cm} + m d^2\), where \(m\) is the total mass in kg. It applies only when one of the two axes passes through the center of mass.
FAQ
Does the axis have to be parallel? Yes. The theorem only applies when the new axis is parallel to the center-of-mass axis. For non-parallel axes you need the full inertia tensor.
What units should I use? Use consistent SI units: mass in kg, distance in m, and inertia in kg\(\cdot\)m². The result will then be in kg\(\cdot\)m².
Can d be zero? Yes. If \(d = 0\) the new axis coincides with the center-of-mass axis, and \(I\) simply equals \(I_{cm}\).